Poster Presentation
LQG solution for POMDP without estimating states: A Minimum Variance Approach
Abstract
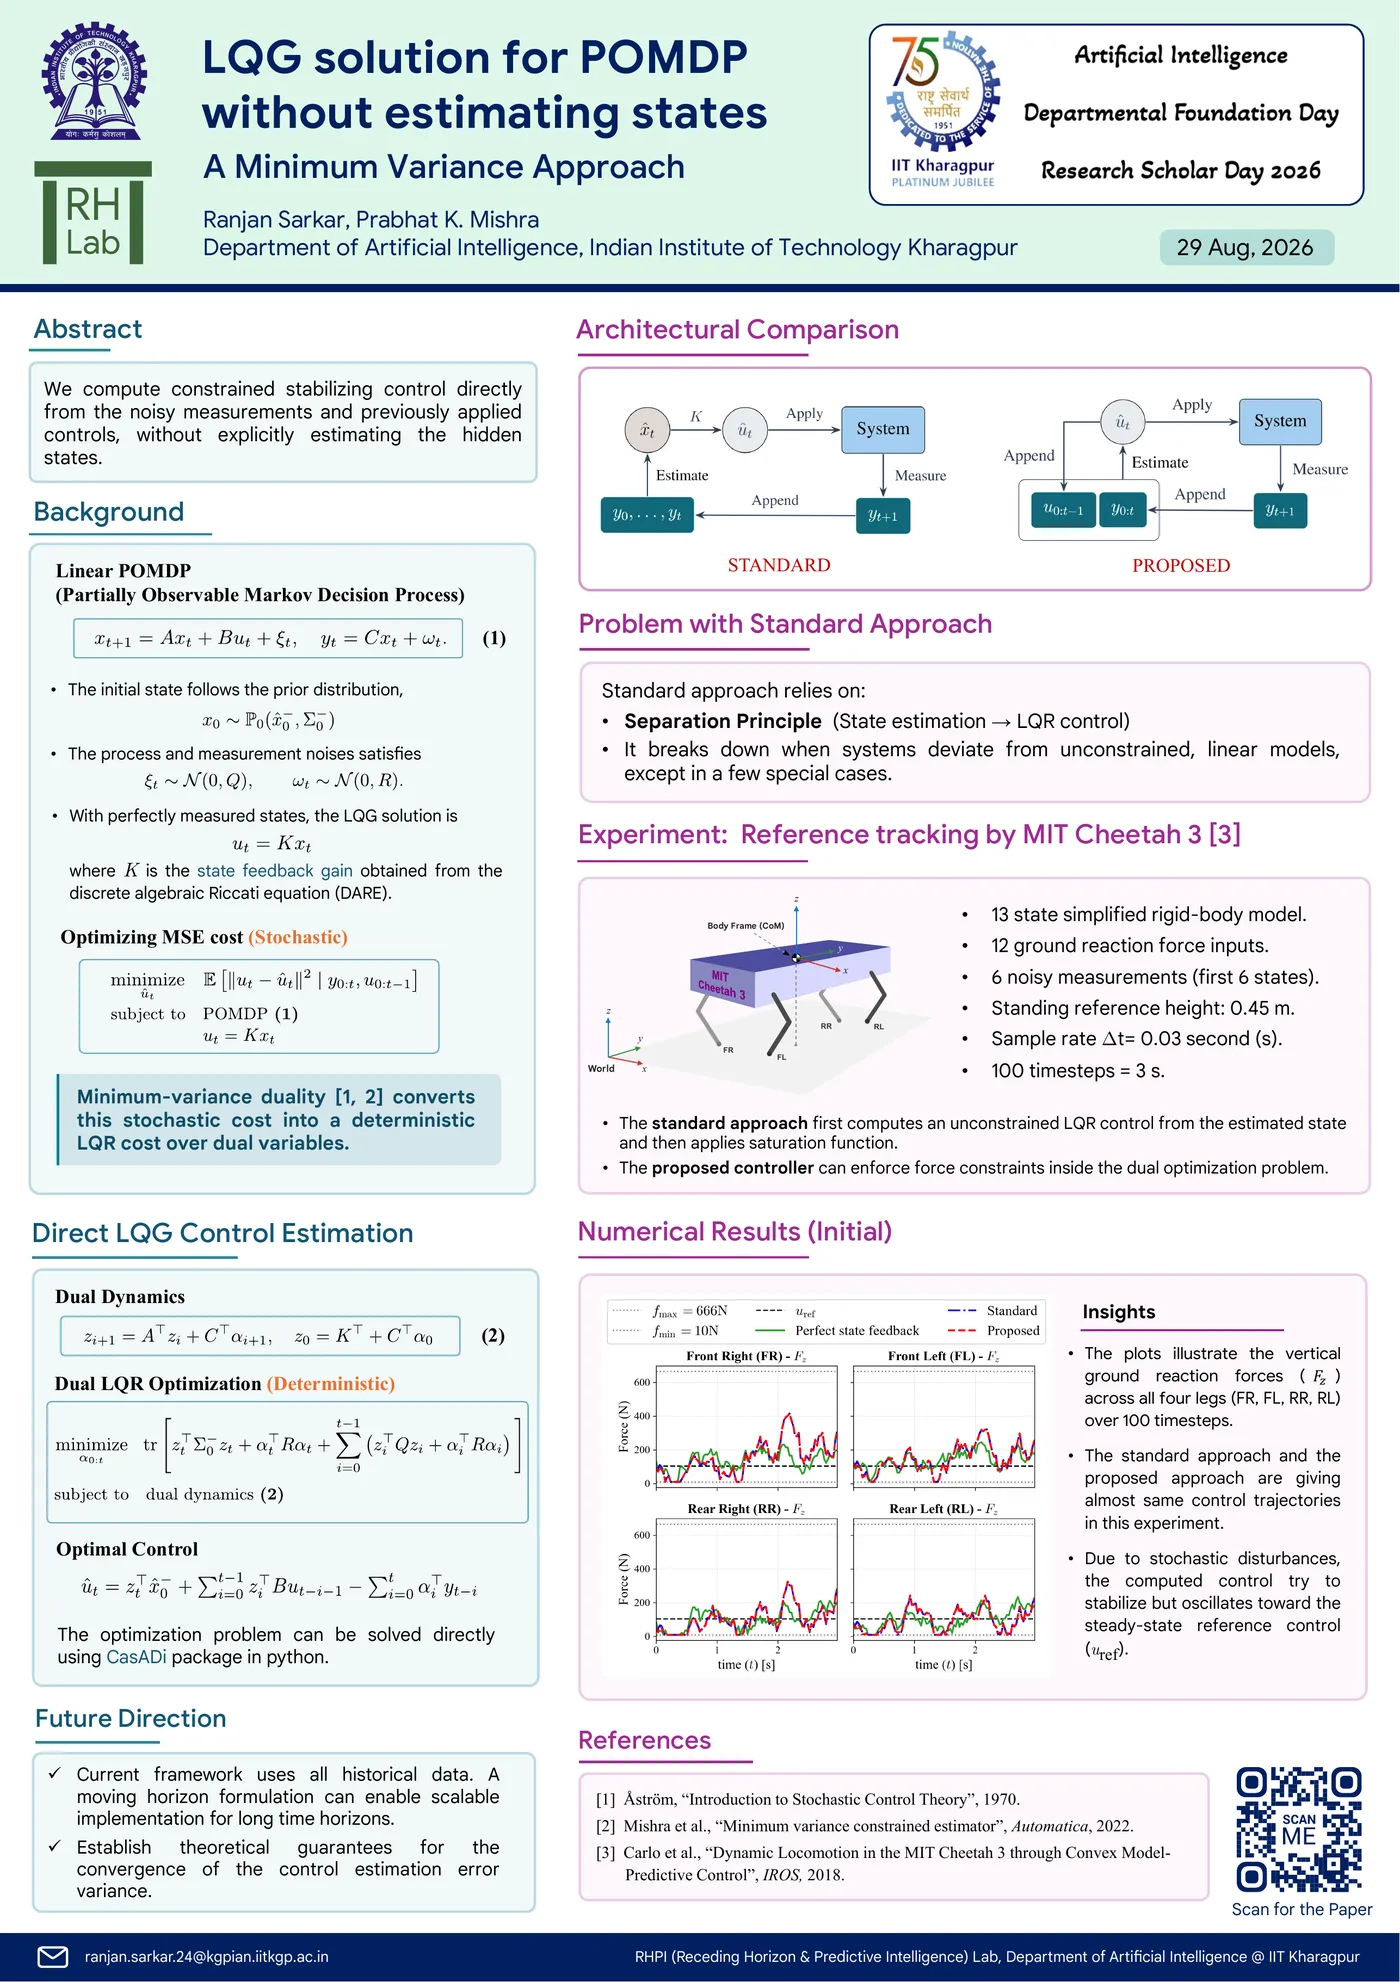
We compute constrained stabilizing control directly from the noisy measurements and previously applied controls, without explicitly estimating the hidden states.
Highlights
- The standard LQG pipeline relies on the separation principle (state estimation → LQR control), which breaks down once the system deviates from an unconstrained, linear model.
- Minimum-variance duality converts the stochastic mean-squared-error control cost into a deterministic LQR cost over dual variables, which is solved directly with CasADi.
- Input constraints are enforced inside the dual optimization problem, instead of saturating an unconstrained LQG law computed from the estimated state.